Annanim News
Now
RoboticsBoston Dynamics puts Atlas on wheels to test whole-body controlQuantum & precision measurementDiraq installs a silicon spin quantum computer in an Equinix commercial data center in SydneyModels & researchMeta launches Muse Ember, a light, cheap model for the repetitive work of AI agentsCybersecurityA lone attacker in Taiwan used AI agents to pull Taipei emergency dispatch recordsGeopolitics & techIsrael plans national AI infrastructure with 300,000 GPUs and an Israeli foundation modelCybersecurityVanta to acquire Israeli AI security company Pillar for about $150 millionCybersecurityFrance blames Iran for supermarket refrigeration attacks that caused 15 firesRegulation & businessReport: Anthropic moves ahead with its IPO and could start trading next weekChinaChina Watch: an 800 MW AI campus in Inner Mongolia, powered by wind and batteriesCybersecurityN-able takes N-central offline after more than 30 vulnerabilities are publishedModels & researchAnthropic launches Claude Fable 5.2 and Mythos 5.2: faster and cheaperChips & hardwareHuawei unveils 'entirely Chinese' desktop PCs with the Kirin X90 CPU and HarmonyOSAutonomous vehiclesTesla launches Robotaxi in San Antonio, its eighth city, with a stated 274-square-mile service areaCybersecurityGoogle DeepMind's AI agents found two ways to make attacks on 1024-bit RSA keys cheaperRegulation & businessReport: Anthropic commits $3.4 billion to 1.7 GW of gas generators

Originally published:

Boston Dynamics puts Atlas on wheels to test whole-body control

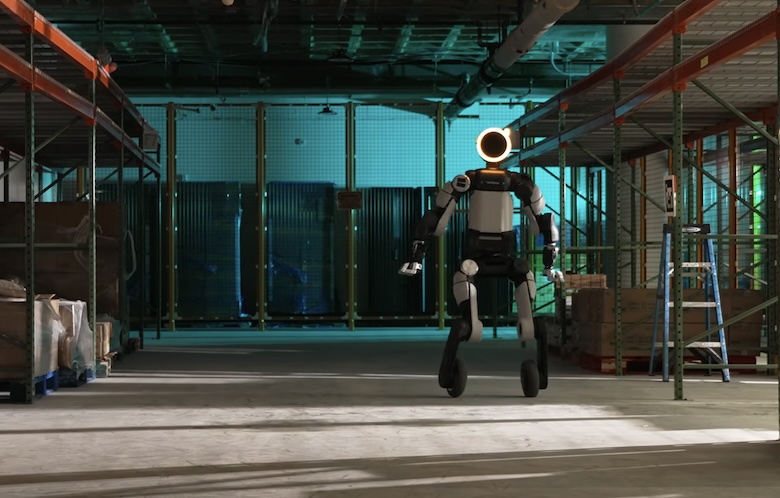
Boston Dynamics released a video of its Atlas humanoid moving on wheels mounted on its legs. The company stresses this is not a product but a research testbed that combines classical model-based control with whole-body reinforcement learning.

Boston Dynamics puts Atlas on wheels to test whole-body control
Image: The Robot Report (opens the source site in a new tab)

In the video, Atlas switches between fast rolling on flat ground and legged walking over obstacles and uneven surfaces, and also performs pirouettes and aggressive maneuvers. Andy Wu, a controls engineer for Atlas, trained all the behaviors in simulation, and they ran on the real robot with surprising accuracy, he said.

According to Wu, the conversion was simple: a single adapter that mounts an off-the-shelf scooter rim onto Atlas's existing ankle actuator is the only new part. In software, each wheel is modeled as an "ankle" that can spin continuously, and the reinforcement learning policy responds in real time to sensor feedback and velocity commands to stay stable against disturbances.

The goal, according to the company, is to push the actuators to their limits and test adaptability to unpredictable environments that are hard to model or simulate. Boston Dynamics says a wheeled Atlas is not a product but a research testbed.

Sources

Topics

Install the app

In Safari: tap the Share button, then “Add to Home Screen”.